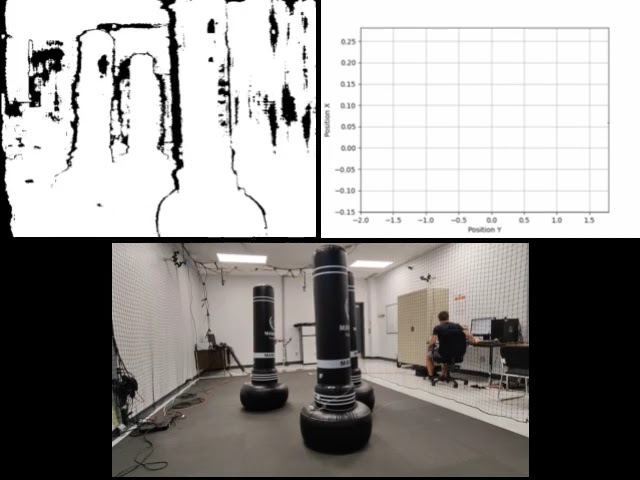
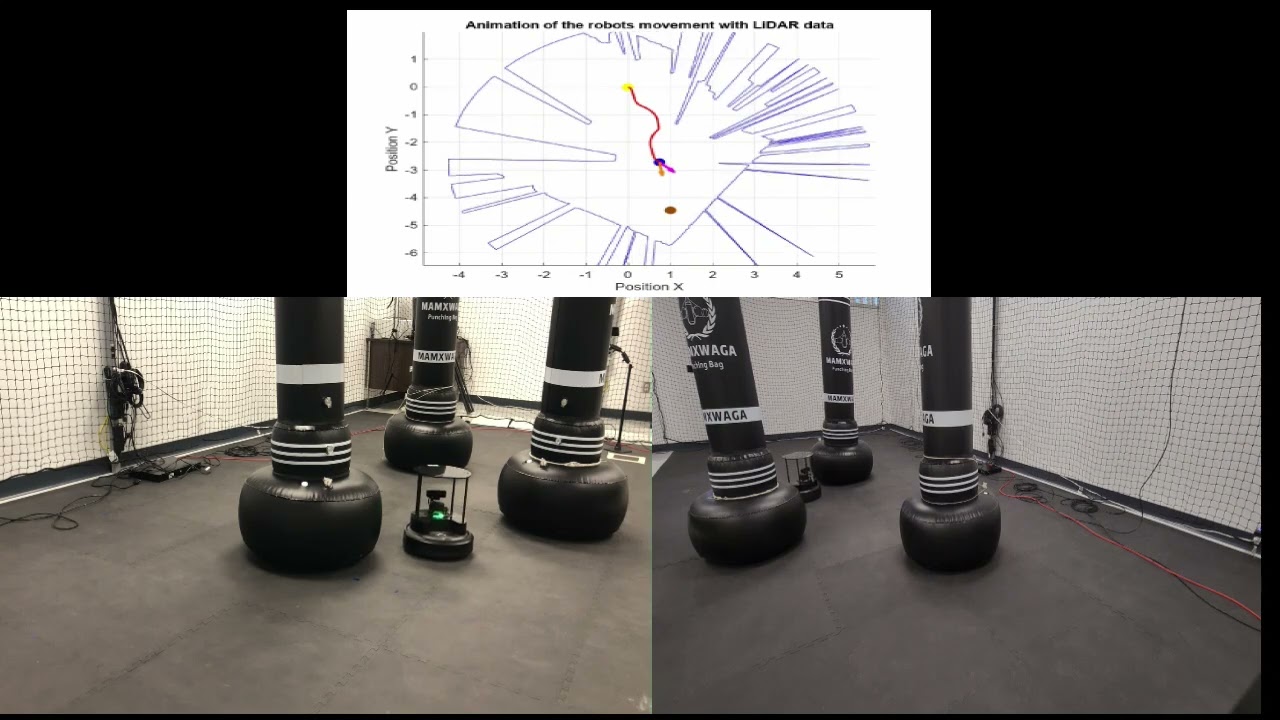
Presenting LaRSA research to CRIAQ visitors at UQO.
Research in practice
Ideas developed together.
Our work connects mathematical analysis, simulation, and robotic implementation. Researchers and students at LaRSA investigate estimation, safe navigation, and coordination for aerial, ground, and marine robots.
Multi-UAV Active Simultaneous Localization and Mapping in Unknown Indoor Environments
In collaboration with McGill University and Queen's University. Localization, mapping, and exploration by groups of unmanned aerial vehicles using vision and inertial sensing with limited onboard computing resources.
NSERC Discovery Grant / 2020–2026
Advancing Autonomy for Unmanned Aerial Vehicles
A research program addressing localization, obstacle avoidance, and mission execution for small aerial vehicles.
UQO startup grant / 2020–2022
Development of Autonomous Navigation Systems for Unmanned Aerial Vehicles
We gratefully acknowledge support from UQO, NSERC, FRQNT, Mitacs, and our industry partners.
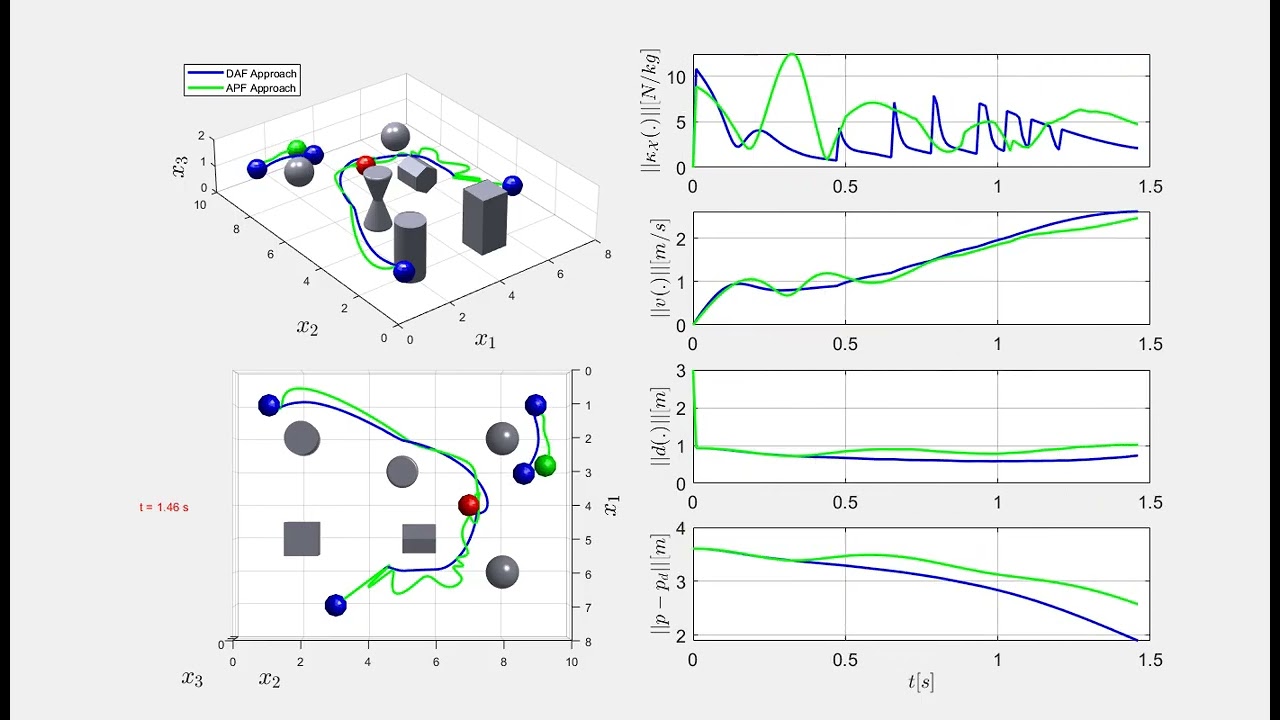
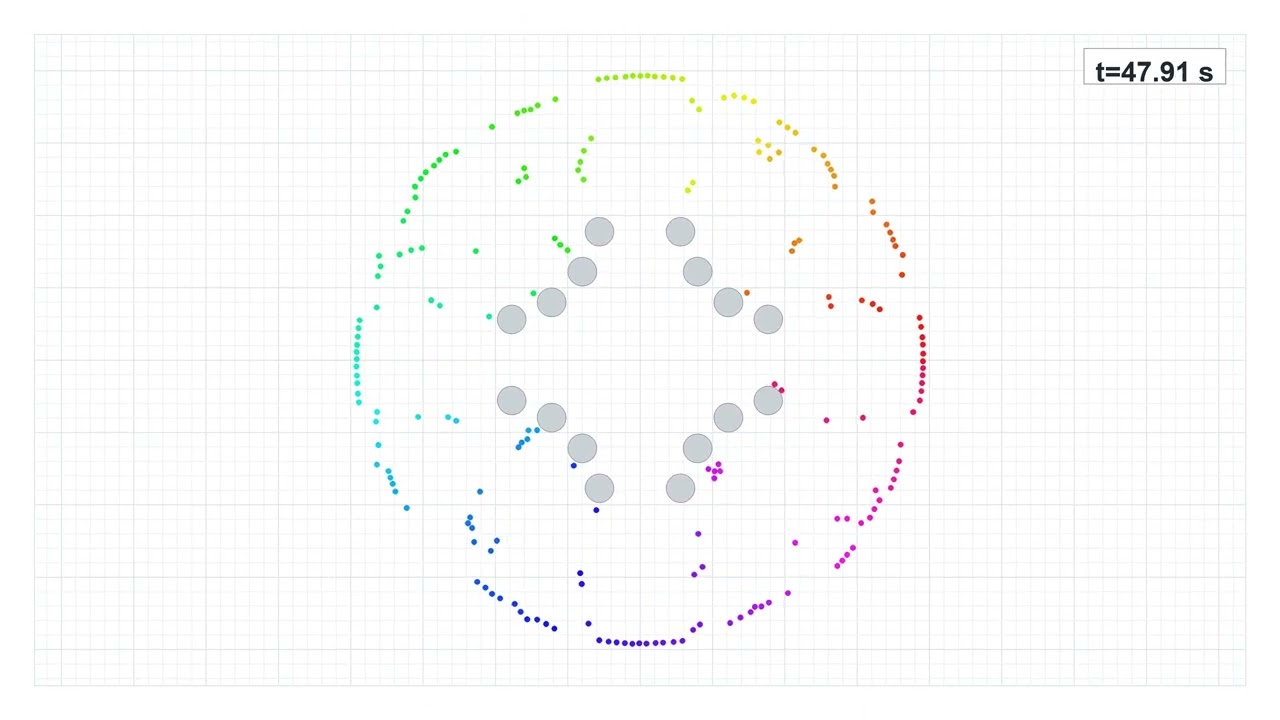 Watch the simulation YouTube ↗