State estimation & navigation
Geometric observers for range-, vision-, magnetic-field-, barometer-, and Pitot-aided inertial navigation.
LaRSA · Université du Québec en Outaouais
Research in state estimation, safe navigation, and coordination for autonomous robotic systems.
LaRSA develops guidance, navigation, and control methods for ground, aerial, and marine robots, connecting mathematical foundations with experimental research.
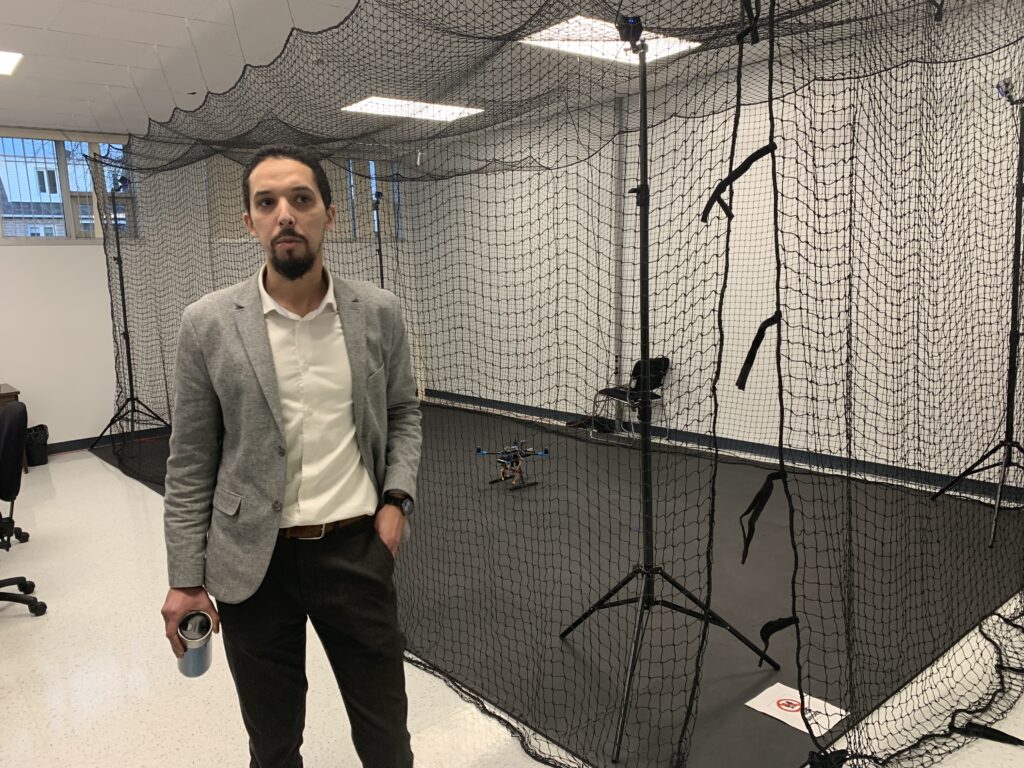
The Laboratoire de Robotique et Systèmes Autonomes (LaRSA) is part of UQO’s Department of Computer Science and Engineering. Founded in 2020 and led by Prof. Soulaimane Berkane, the laboratory studies estimation and control algorithms with guarantees for stability, safety, and robustness.
Geometric observers for range-, vision-, magnetic-field-, barometer-, and Pitot-aided inertial navigation.
Reactive navigation and obstacle avoidance that reconcile collision prevention with convergence.
Distributed estimation, formation control, and reactive collision avoidance for teams of robots.
Geometric feedback design, attitude control, and hybrid methods for the dynamics of robotic systems.
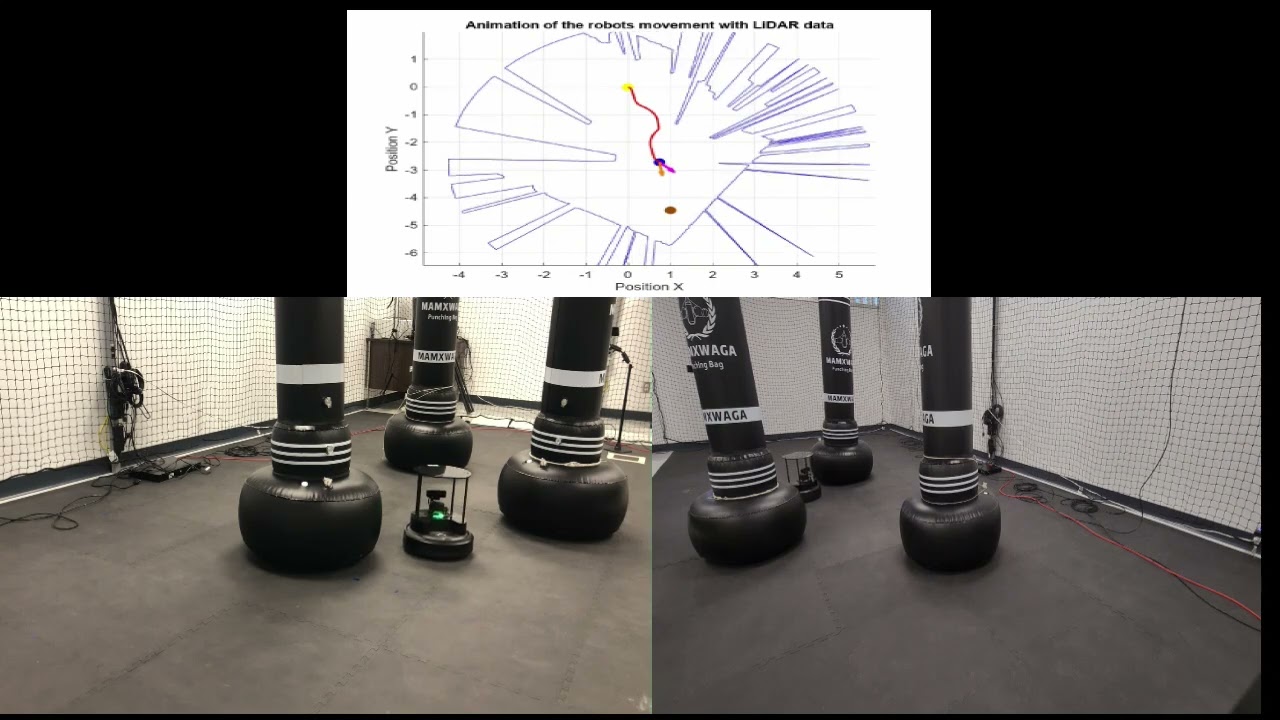 Robot experiment Watch on YouTube ↗
Safety Velocity Cones on TurtleBot 4.
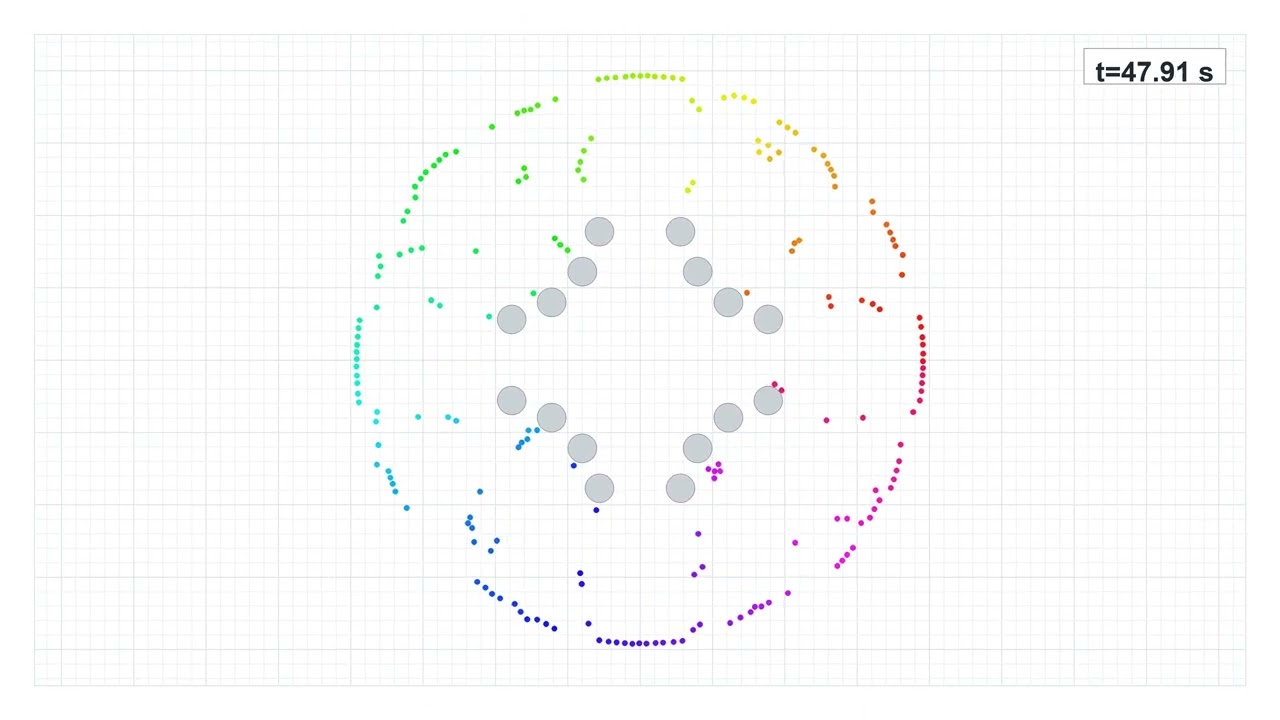 Multi-agent simulation Watch on YouTube ↗
Coordinated motion through narrow passages.
Lyes Smaili and Soulaimane Berkane · Automatica
Mouaad Boughellaba, Soulaimane Berkane, and Abdelhamid Tayebi · IEEE Transactions on Automatic Control
Ishak Cheniouni, Soulaimane Berkane, and Abdelhamid Tayebi · IEEE Transactions on Control Systems Technology
The public preprint is available in the accepted and forthcoming section of the bibliography.
A look inside the laboratory and its research activities.
For research enquiries, collaboration, or graduate study, contact Prof. Soulaimane Berkane. Prospective students can find guidance on the joining the laboratory page.